

Product Description
Key Features
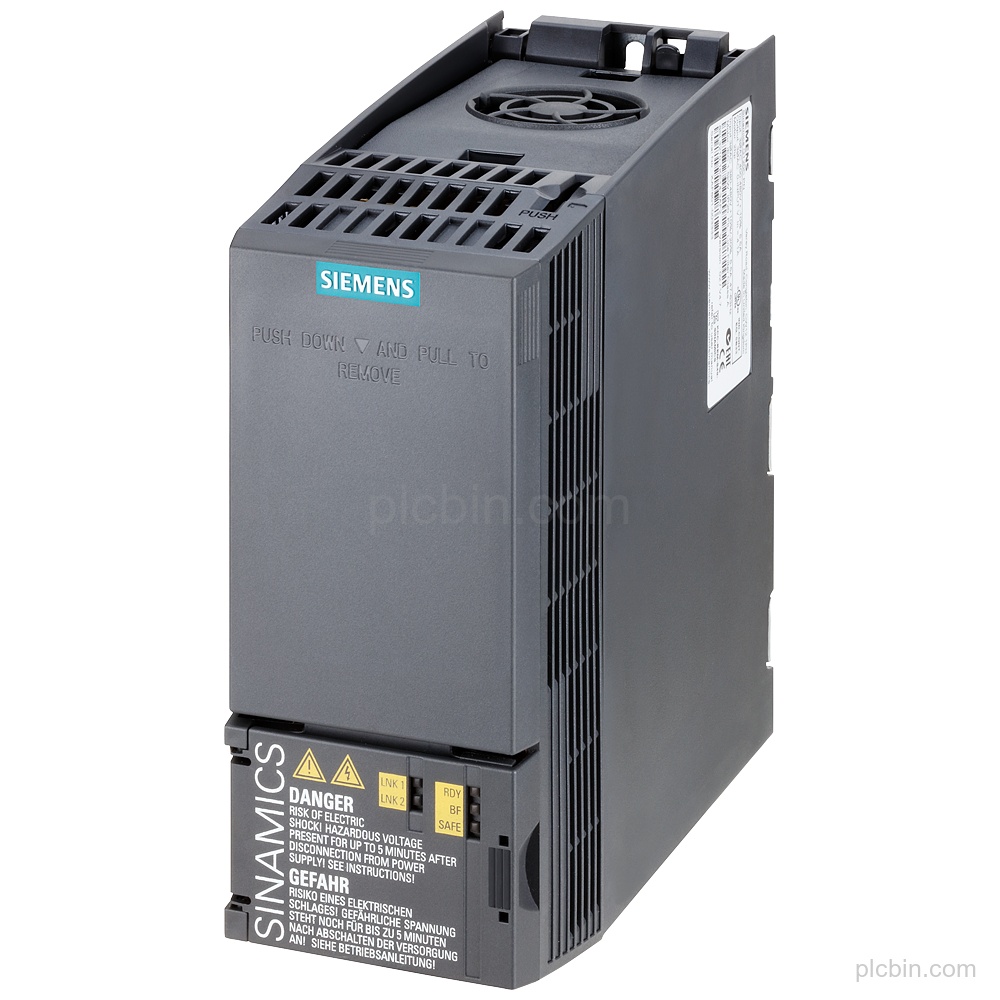
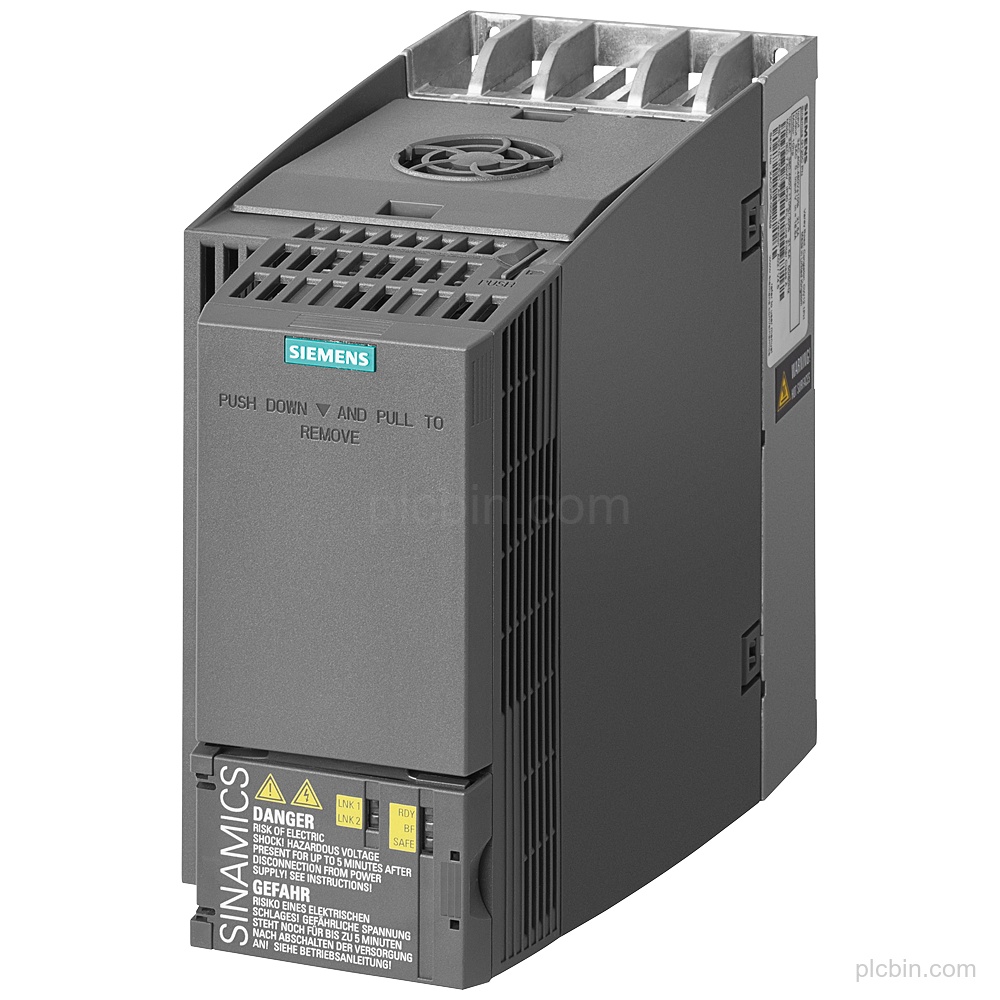
- Exact converter identity: SINAMICS G120C converter, order number 6SL3210-1KE21-3AP1, with Active Product lifecycle data.
- Rated power and overload: Low overload: 5.50 kW at 150% for 3s, 110% for 57s and 100% for 240s. High overload: 4.00 kW at 200% for 3s, 150% for 57s and 100% for 240s.
- Supply and communication: Input: 3 AC, 380 … 480 V +10 % -20 %, 47 … 63 Hz. Communication: PROFIBUS DP.
- I/O configuration: 6 standard digital inputs, 1 fail-safe digital input, 1 relay changeover contact, 1 transistor output, 1 differential analog input and 1 non-isolated analog output.
- Connections and mounting: Plug-in screw terminals are provided on the line side, motor end and DC link. Frame size: FSB; width: 100 mm (3.94 in), depth: 203 mm (7.99 in).
- Protection and lifecycle: Integrated Class A filter and IP20 / UL open type protection. The supplied lifecycle status is Active Product.
Technical Summary
| Rated power (LO) | 5.50 kW | 7.50 hp |
|---|---|
| Rated power (HO) | 4.00 kW | 5.00 hp |
| Input | 3 AC, 380 … 480 V +10 % -20 %, 47 … 63 Hz |
| Communication | PROFIBUS DP |
| I/O | 6DI, 2DO, 1AI, 1AO, 1 fail-safe digital input |
| Max. output current | 17.60 A |
| Output frequency for vector control | 0 … 240 Hz |
| Output frequency for V/f control | 0 … 550 Hz |
| Connections | Plug-in screw terminals; DC link line length, max.: 15 m (49.21 ft) |
| Protection | IP20 / UL open type |
| Frame size | FSB |
| Lifecycle | Active Product |
Frequently Asked Questions
What order number should be confirmed for this Siemens converter?
Confirm 6SL3210-1KE21-3AP1 on the nameplate or installed-part record.
Which communication interface does this configuration have?
It has PROFIBUS DP communication.
What I/O configuration should be checked?
Check for 6 standard digital inputs, 1 fail-safe digital input, 1 relay changeover contact, 1 transistor output, 1 differential analog input and 1 non-isolated analog output.
Does this configuration include encoder feedback or encoderless torque control?
It is without vector control with sensor, encoderless torque control and torque control with encoder.